Design of an Artificial Neural Network Based Tactile Sensor for the UTAH/MIT Dexterous Hand
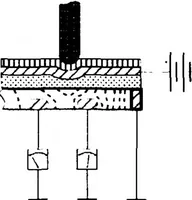
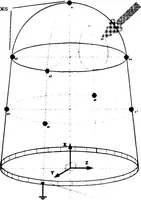
This 1992 technical report by the Air Force Institute of Technology, distributed through the Defense Technical Information Center, describes a neural-network tactile sensor built for the UTAH/MIT dexterous robot hand. The pictures are plain line diagrams of sensing setups: a grid of electrodes beneath a flexible layer, a pressing probe on a layered skin, a single contact with a battery and meter, and a dome-shaped arrangement of marked points over a circular base. A designer might take the clean, schematic linework and the layered cross-section method for showing how touch is sensed.